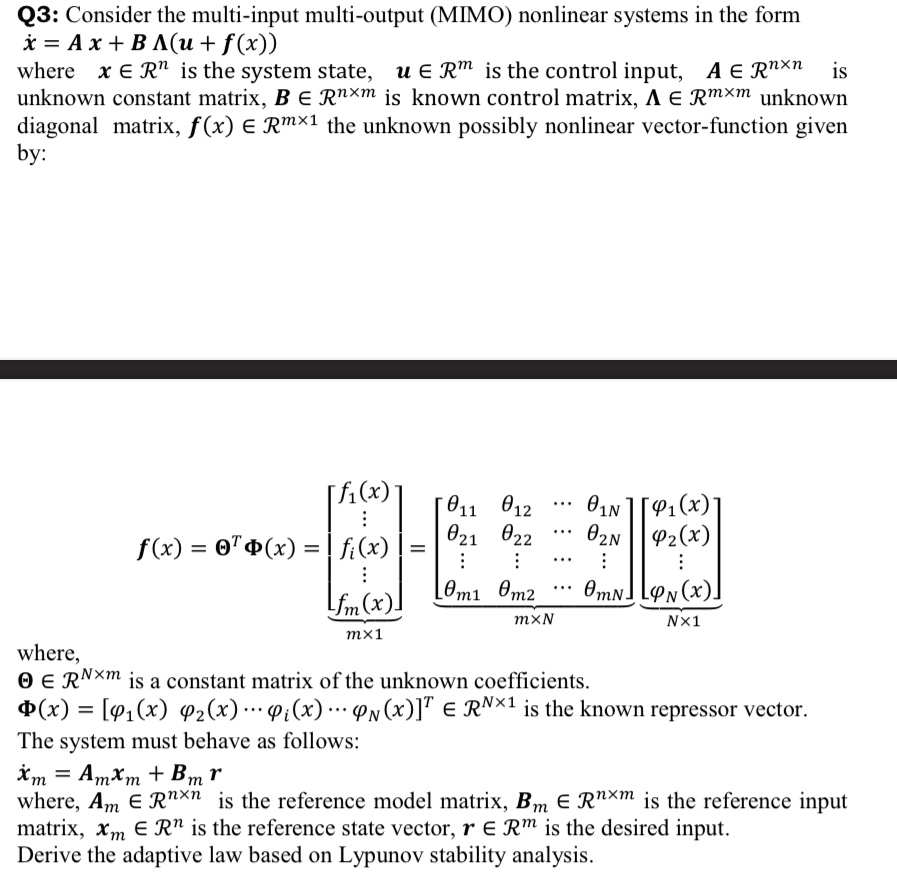
Q3: Consider the multi-input multi-output (MIMO) nonlinear systems in the form x = A*x + B*A*(u + f(x)).
Here, A is an unknown constant matrix, B ∈ R^(n×m) is a known control matrix, A ∈ R^(m×m) is an unknown diagonal matrix, and f(x) ∈ R^(m×1) is the unknown possibly nonlinear vector-function given by:
[fi(x) [0 1 1 ... 0 1 2 ... 0 1 N]
0 2 1 ... 0 2 2 ... 0 2 N
...
0 m 1 ... 0 m 2 ... 0 m N]
where,
N(x) = [f1(x) : f2(x) : ... : fm(x)]^T is an m×N matrix.
The system must behave as follows:
im = Am*xm + Bm*r
where, Am ∈ R^(n×n) is the reference model matrix, Bm ∈ R^(n×m) is the reference input matrix, xm ∈ R^n is the reference state vector, and r ∈ R^m is the desired input.
Derive the adaptive law based on Lyapunov stability analysis.