Semester: Fall 2014
Student Name:
Registration Number:
Introduction to Robotics (MEEG 485)
Quiz (4): Inverse Kinematics
Section:
Serial Number:
Date:
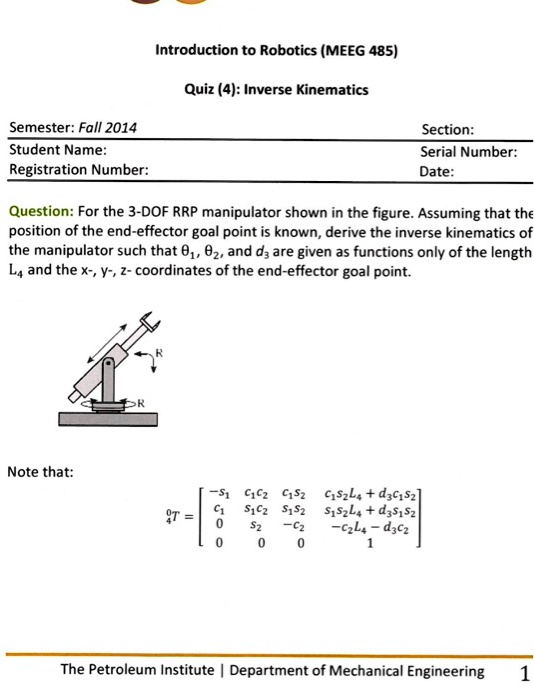
Question: For the 3-DOF RRP manipulator shown in the figure. Assuming that the
position of the end-effector goal point is known, derive the inverse kinematics of
the manipulator such that $\theta_1$, $\theta_2$, and $d_3$ are given as functions only of the length
$L_4$ and the x-, y-, z- coordinates of the end-effector goal point.
Note that:
$^0_4T = \begin{bmatrix} -S_1 & C_1C_2 & C_1S_2 & C_1S_2L_4 + d_3C_1S_2 \\ 0 & S_1C_2 & S_1S_2 & S_1S_2L_4 + d_3S_1S_2 \\ 0 & S_2 & -C_2 & -C_2L_4 - d_3C_2 \\ 0 & 0 & 0 & 1 \end{bmatrix}$
The Petroleum Institute | Department of Mechanical Engineering
1