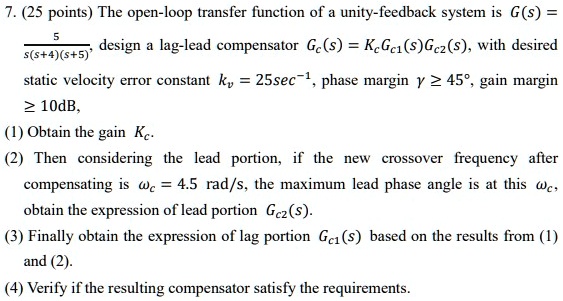
7. (25 points) The open-loop transfer function of a unity-feedback system is $G(s) = \frac{5}{s(s+4)(s+5)}$, design a lag-lead compensator $G_c(s) = K_cG_{c1}(s)G_{c2}(s)$, with desired static velocity error constant $k_v = 25 sec^{-1}$, phase margin $\gamma \ge 45^\circ$, gain margin $\ge 10dB$,
(1) Obtain the gain $K_c$.
(2) Then considering the lead portion, if the new crossover frequency after compensating is $\omega_c = 4.5 rad/s$, the maximum lead phase angle is at this $\omega_c$, obtain the expression of lead portion $G_{c2}(s)$.
(3) Finally obtain the expression of lag portion $G_{c1}(s)$ based on the results from (1) and (2).
(4) Verify if the resulting compensator satisfy the requirements.