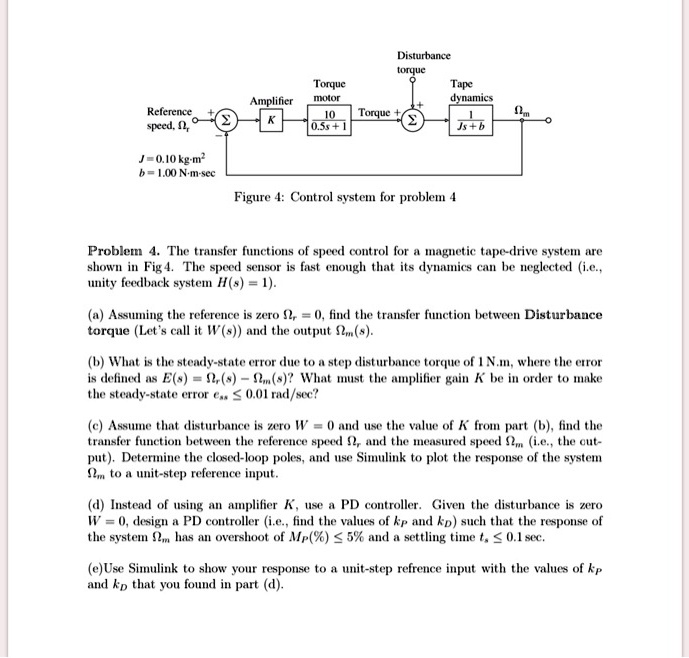
Disturbance torque Tape motor dynamics 10 Torque 0.5s+
Amplifier K
Reference speed,
m
J=0.10 kg-m^2 b=1.00 N-m-sec
Figure 4: Control system for problem 4
Problem 4: Transfer Functions and Control System Analysis
The transfer functions of speed control for a magnetic tape-drive system are shown in Figure 4. The speed sensor is fast enough that its dynamics can be neglected (i.e., unity feedback system H(s) = 1).
a) Assuming the reference is zero, find the transfer function between Disturbance torque (Ws) and the output ms.
b) What is the steady-state error due to a step disturbance torque of 1 N.m, where the error steady-state error e = 0.01 rad/sec?
c) Assume that disturbance is zero (W = 0) and use the value of K from part (b), find the transfer function between the reference speed and the measured speed (mi.e., the output). Determine the closed-loop poles and use Simulink to plot the response of the system Am to a unit-step reference input.
d) Instead of using an amplifier K, use a PD controller. Given the disturbance is zero (W = 0), design a PD controller (i.e., find the values of kp and kp such that the response of the system m has an overshoot of Mp% = 5% and a settling time t, = 0.1 sec.
e) Use Simulink to show your response to a unit-step reference input with the values of kp and kp that you found in part d.