1) 25 Points
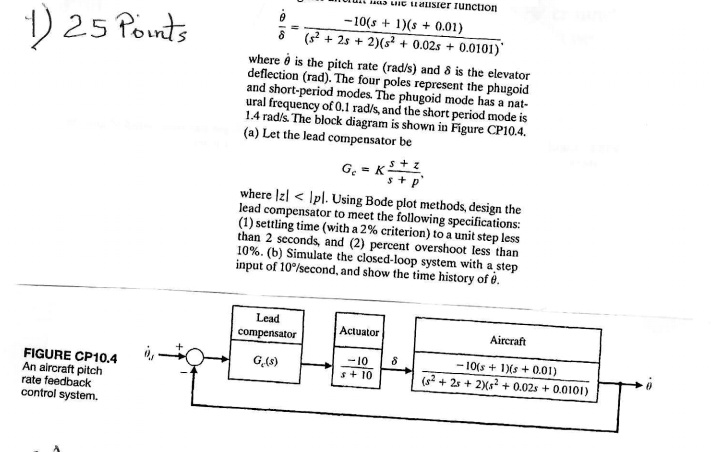
FIGURE CP10.4
An aircraft pitch
rate feedback
control system.
\frac{\dot{\delta}}{\delta} = \frac{-10(s+1)(s+0.01)}{(s^2+2s+2)(s^2+0.02s+0.0101)}
where $\dot{\delta}$ is the pitch rate (rad/s) and $\delta$ is the elevator
deflection (rad). The four poles represent the phugoid
and short-period modes. The phugoid mode has a nat-
ural frequency of 0.1 rad/s, and the short period mode is
1.4 rad/s. The block diagram is shown in Figure CP10.4.
(a) Let the lead compensator be
$G_c = K\frac{s+z}{s+p}$
where $|z| < |p|$. Using Bode plot methods, design the
lead compensator to meet the following specifications:
(1) settling time (with a 2% criterion) to a unit step less
than 2 seconds, and (2) percent overshoot less than
10%. (b) Simulate the closed-loop system with a step
input of 10°/second, and show the time history of $\delta$.